I am a Ph.D. candidate at KAIST AI, advised by Prof. Hyunjung Shim. I received my B.S. in Mechanical Engineering & Artificial Intelligence from Korea University.
My research focuses on Physical AI & LLMs. I have been working on autonomous driving, vision-language models (VLMs), and LiDAR perception. I am interested in building AI systems that can understand and interact with the physical world. Recently, I’m interested in unifying various tasks and embodiments on a single VLA/WAM model.
News
- [10/2026] Recognized as a Top Reviewer at NeurIPS 2026 (Main Track).
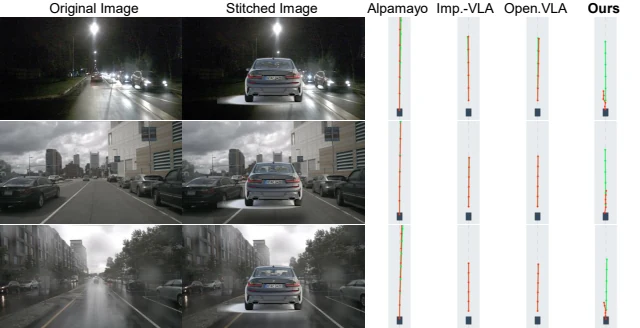
- [09/2026] Grounding Driving VLA via Inverse Kinematics is accepted to NeurIPS 2026.
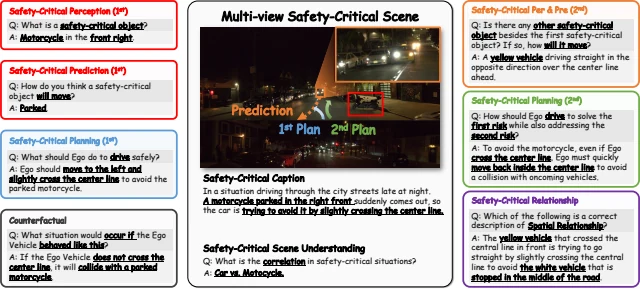
- [08/2026] WaymoQA is accepted to EMNLP 2026 Findings.
- [05/2026] Joined Qualcomm AI Research (Qualcomm Korea YH) as a research intern.
- [10/2025] Our team placed 4th in the IROS 2025 RoboSense Challenge, Track 1: Driving with Language.
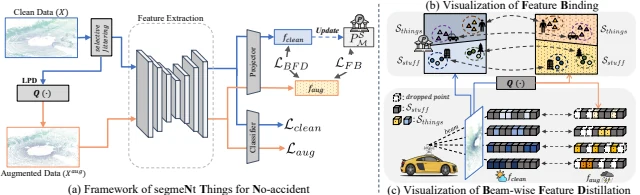
- [05/2025] No Thing, Nothing is accepted to CVPR 2025.
- [04/2025] Gave an invited talk at the AI Tutorial Series, Seoul AI Hub.
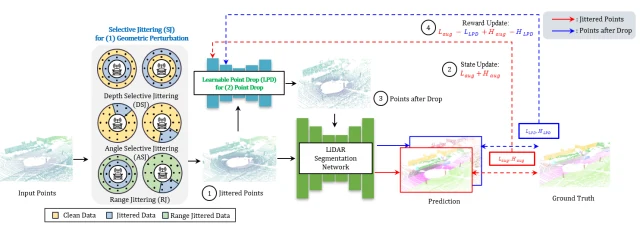
- [03/2024] Rethinking Data Augmentation for Robust LiDAR Segmentation is accepted to ECCV 2024 as an oral presentation.
Publications
* equal contribution
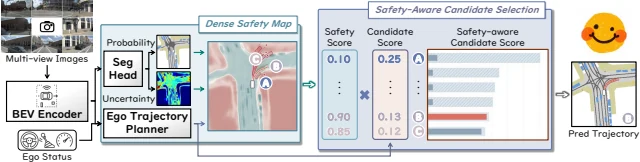
SUPER-AD: Semantic Uncertainty-aware Planning for End-to-End Robust Autonomous Driving
Preprint, 2025
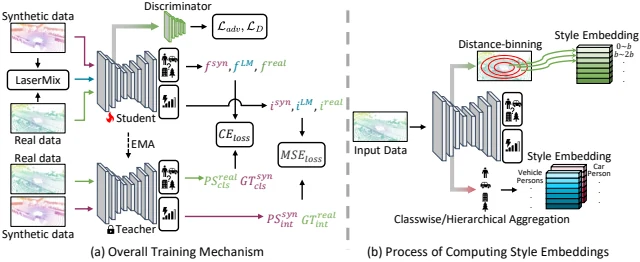
Scene, Class, Signal: Tri-Level Adaptation for Synthetic-to-Real LiDAR Segmentation
Preprint, 2025
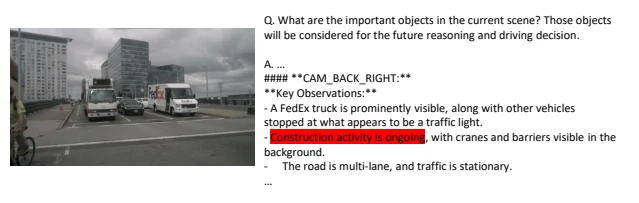
Robust Driving QA through Metadata-Grounded Context and Task-Specific Prompts
IROS 2025 Workshop, RoboSense Challenge, 2025
Education & Experience
- May 2026 – Nov 2026Research Intern, Qualcomm AI Research, Qualcomm Korea YH
Investigate reasoning faithfulness in driving vision-language-action (VLA) models. - 2023 – PresentPh.D. Candidate in Artificial Intelligence, Korea Advanced Institute of Science and Technology (KAIST)
- 2017 – 2023B.S. in Mechanical Engineering & Artificial Intelligence, Korea University
Talks
- Apr 2025Invited Talk, AI Tutorial Series, Seoul AI Hub
Rethinking Data Augmentation for Robust LiDAR Semantic Segmentation in Adverse Weather - Sep 2024Oral Presentation, ECCV 2024
Rethinking Data Augmentation for Robust LiDAR Semantic Segmentation in Adverse Weather
Patents
- 2024Barbell with Built-in Weight Fixing Device
Korea Patent, Reg. No. 1026314710000 (App. No. 10-2021-0092158)
Projects
- 2025IROS 2025 RoboSense Challenge, Track 1: Driving with Language [PDF]
Developed a prompting method that helps VLMs understand driving scenes. Placed 4th. - 2022Open Manipulator Grasping Task: Vision for Robot Arm Control [Code]
Undergraduate project. Vision modules for robot-arm grasping; 3D grasp position from FCN segmentation and a pinhole camera model. - 2021
- 2021Mobile Robot Project: ROS Programming & Motor Control [Code]
Undergraduate project. ROS1 programming and embedded motor control on an OpenCM board. - 2018Capstone Design: Stair Treads Wheels [PDF]
Undergraduate project. Designed stair-climbing wheels and their rotation control. Bronze Prize.
Awards & Honors
- 2022 – 2023Scholarship, Lee Myungbak & Kim Yoonok Foundation
- 2021 – 2023Scholarship, Korea University Alumni Association
- 2018Bronze Prize & Social Contribution Prize, Capstone Design Project, Korea Univ. Innovation Center for Engineering
Teaching
- Spring 2026AI 621: Computational Photography, Teaching Assistant, KAIST
- Fall 2025AI 504: Programming for AI, Teaching Assistant, KAIST
- Spring 2025AI 621: Computational Photography, Teaching Assistant, KAIST
- Fall 2024AI 503: Math for AI, Teaching Assistant, KAIST
- Spring 2024AI 611: Deep Reinforcement Learning, Teaching Assistant, KAIST
Academic Services
Conference Reviewer
- NeurIPS 2026 (Top Reviewer, Main Track)
- ICLR 2026
- AAAI 2025
Lab Service
- Student Lab Leader, Prof. Hyunjung Shim's Lab, KAIST (Jul 2024 – May 2025)
- Research Server Administrator (sole administrator), Prof. Hyunjung Shim's Lab, KAIST (Aug 2023 – May 2025)